Soft Robotic Actuation
Pneumatic actuators for controllable, multidimensional movement.
Producing movement through pressure and geometry.
Soft Robotic Actuation investigates air-based actuators for macroscopic movement. Airtight chambers are made from flat fabrics or foils; their geometry and construction influence how they change shape when pressurised.
The project explores how these elements can be combined into apparatuses capable of movement in multiple directions. Material behaviour, the pattern of a chamber and the system controlling its pressure are developed together.
The arm prototype in motion.
From welded material to a controlled prototype.
I developed the concept, design, hardware, software and prototypes during research at the Materiability Research Group at Anhalt University of Applied Sciences. allesblinkt supported the development of custom electronics.
The work included pressure-control systems and software, as well as experiments with welding techniques. The goal was to link a material sample’s movement to a system that could be controlled and compared across tests.
Material
Explore fabrics, foils and airtight joining.
Geometry
Develop chamber patterns for movement.
Control
Build pressure-control hardware and software.
03 / Prototype development
Comparing patterns before combining them.
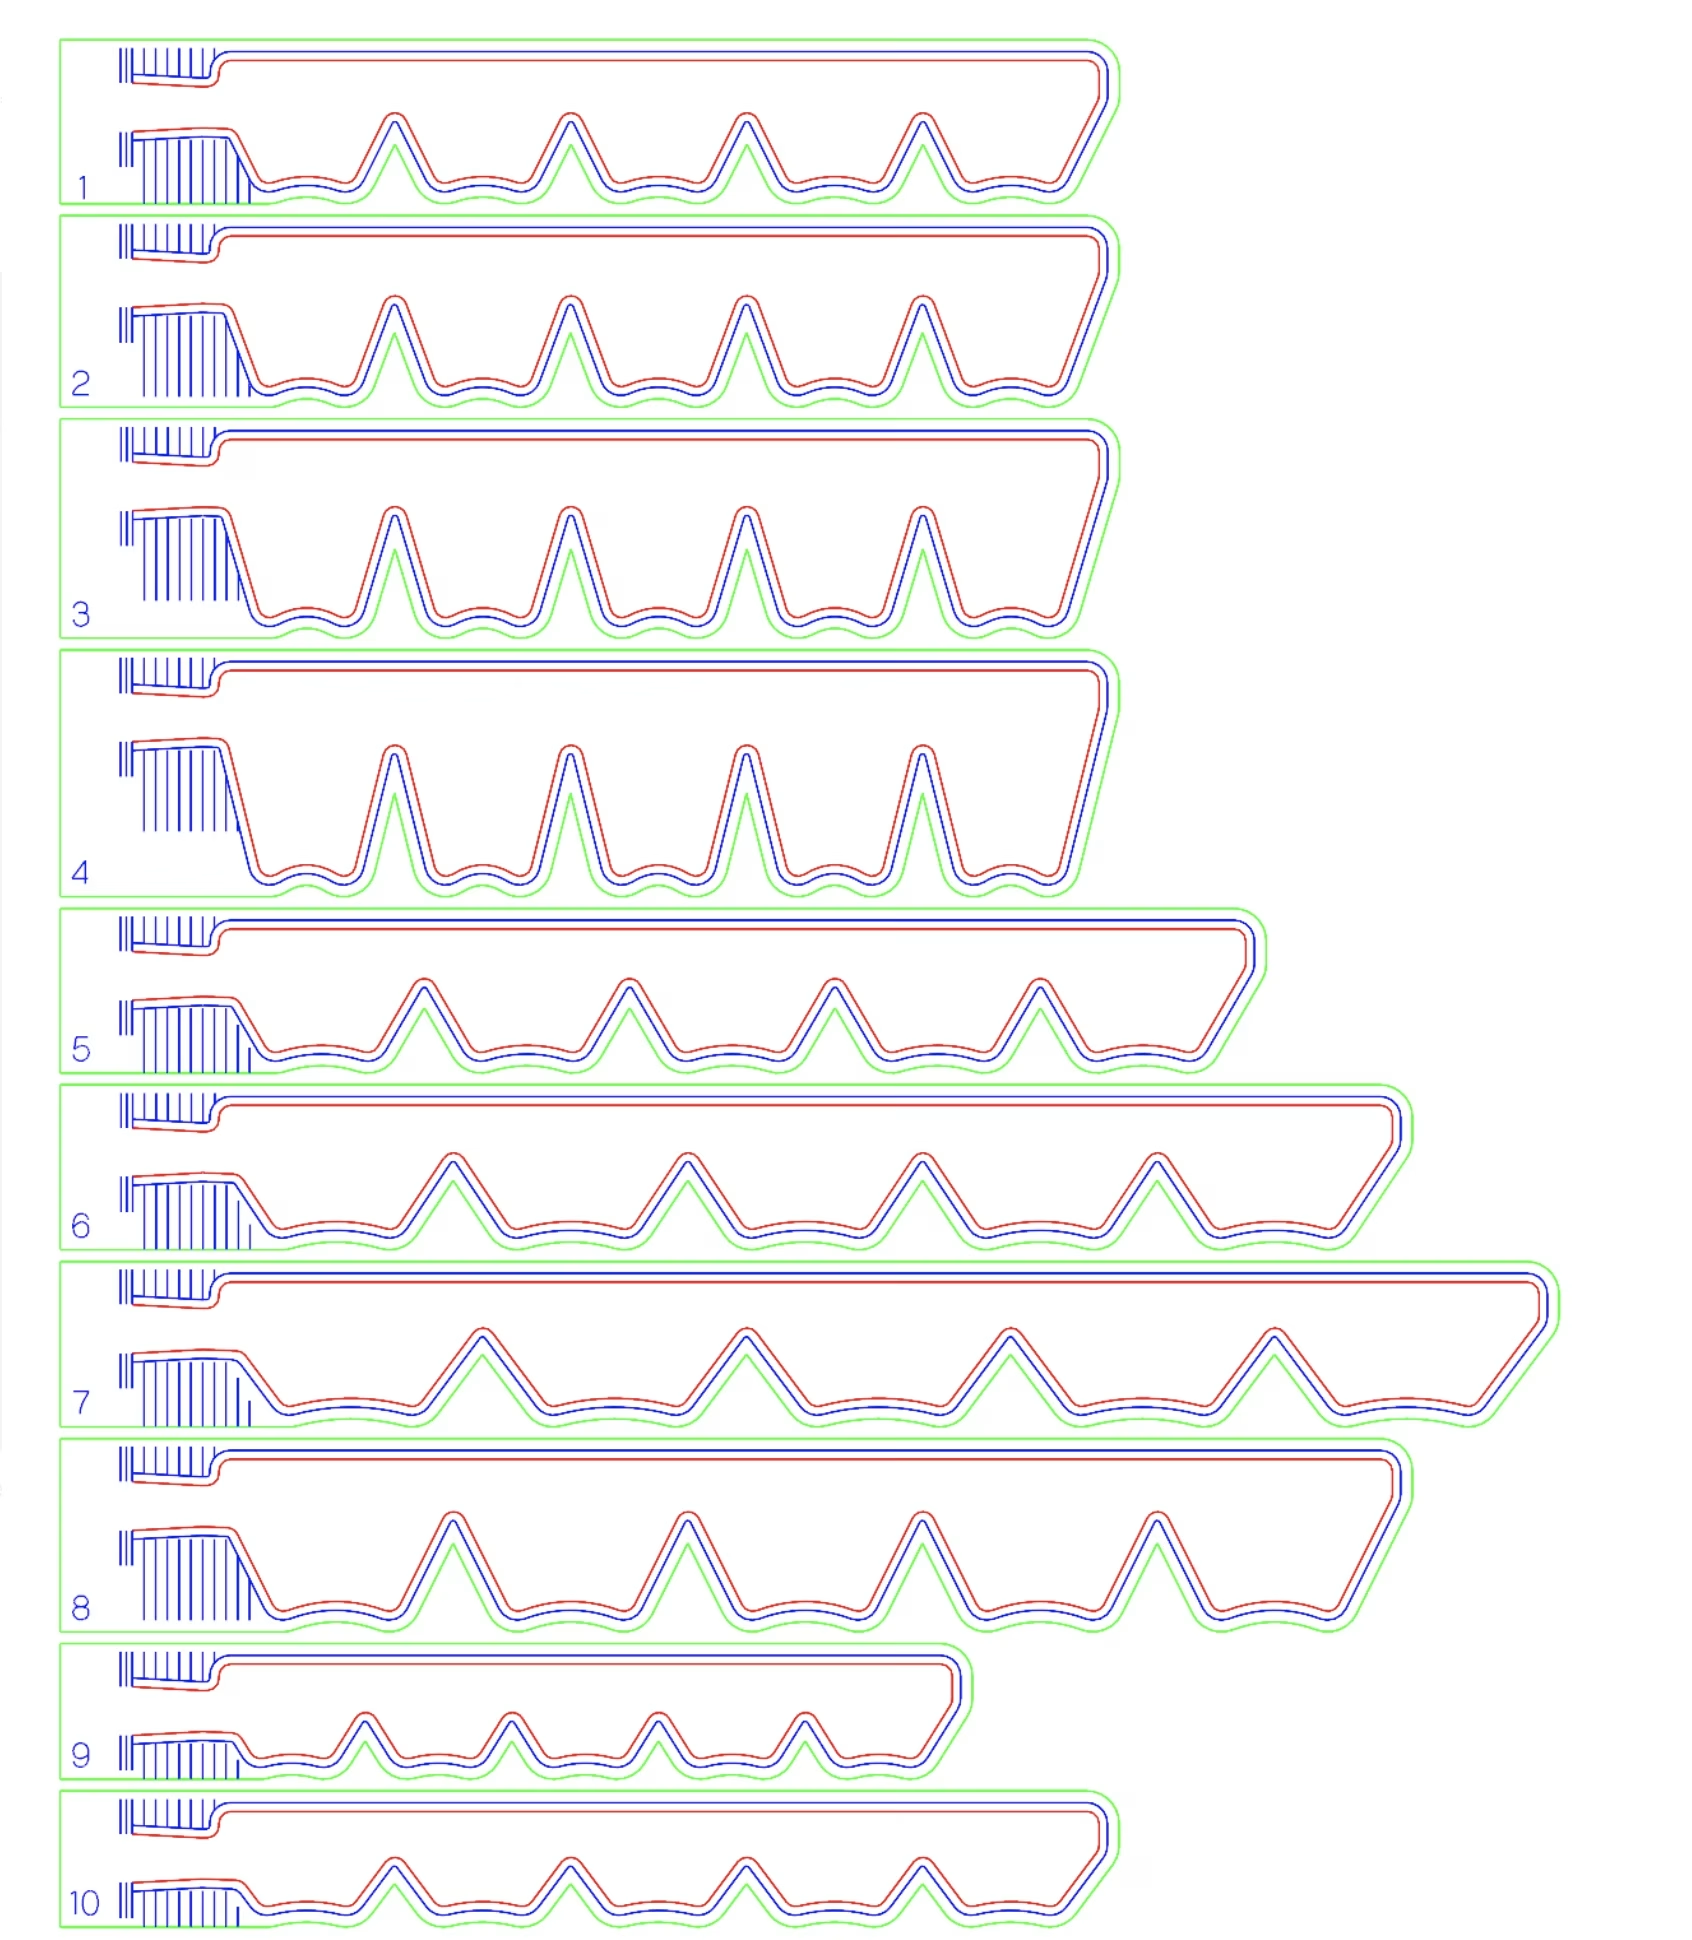
The sample series places alternative chamber geometries side by side. Their outlines and internal joins establish different ways for a flat material to deform under pressure.
The corresponding digital patterns connect those tests to their fabrication. Keeping the sequence visible makes it possible to examine the design of an actuator as a series of choices rather than a single finished shape.
The sample series and comparison plot of pressure curves belong with the Comparison video. Viewed together, they connect differences in the physical patterns to the documented behaviour during testing.
Comparing actuator behaviour.
Connecting air, electronics and software.
The pictures below show the pneumatic connections, electronics and a dedicated enclosure with air inlet and outlet ports. These parts provide the infrastructure behind the apparently simple bending of the material.
The arm prototype brings several elements together in a suspended assembly. It demonstrates the transition from a sample that changes shape to a larger apparatus whose movement depends on coordinated actuation.
The arm as the main demonstrator.
The arm prototype is the main demonstrator: it brings the actuator development and control system together in a moving assembly. The Robot Arm clip shows the complete prototype in operation.
Developed in 2023–24, the project also connects to Sonic Envelopes, where the question extends from producing movement to changing a space’s acoustic properties.
Further reading & related projects